Haochen Shi

I graduated from Stanford University with a Ph.D. in Computer Science, advised by C. Karen Liu and Shuran Song. During my Ph.D., I built ToddlerBot, an open-source humanoid, from scratch and used the platform to study whole-body control, compliant manipulation, and real-world learning.

During my Master's at Stanford, I studied deformable object manipulation with Jiajun Wu, Huazhe Xu, and Yunzhu Li. Previously, during undergraduate at UW-Madison, my work with Michael Gleicher and Danny Rakita explored motion planning algorithms for robots.

Email  /  Google Scholar  /  X  /  GitHub

Haochen Shi

Research

ToddlerBot: Open-Source ML-Compatible Humanoid Platform for Loco-Manipulation

Haochen Shi*, Weizhuo Wang*, Shuran Song, C. Karen Liu

*Equal contribution, Equal advising

CoRL, 2025

An open-source humanoid robot platform for learning locomotion and manipulation skills. Hardware designs, control software, and training code are available on GitHub.
RoboCook: Long-Horizon Elasto-Plastic Object Manipulation with Diverse Tools

Haochen Shi*, Huazhe Xu*, Samuel Clarke, Yunzhu Li, Jiajun Wu

*Equal contribution

CoRL, 2023

Best Systems Paper · CoRL 2023

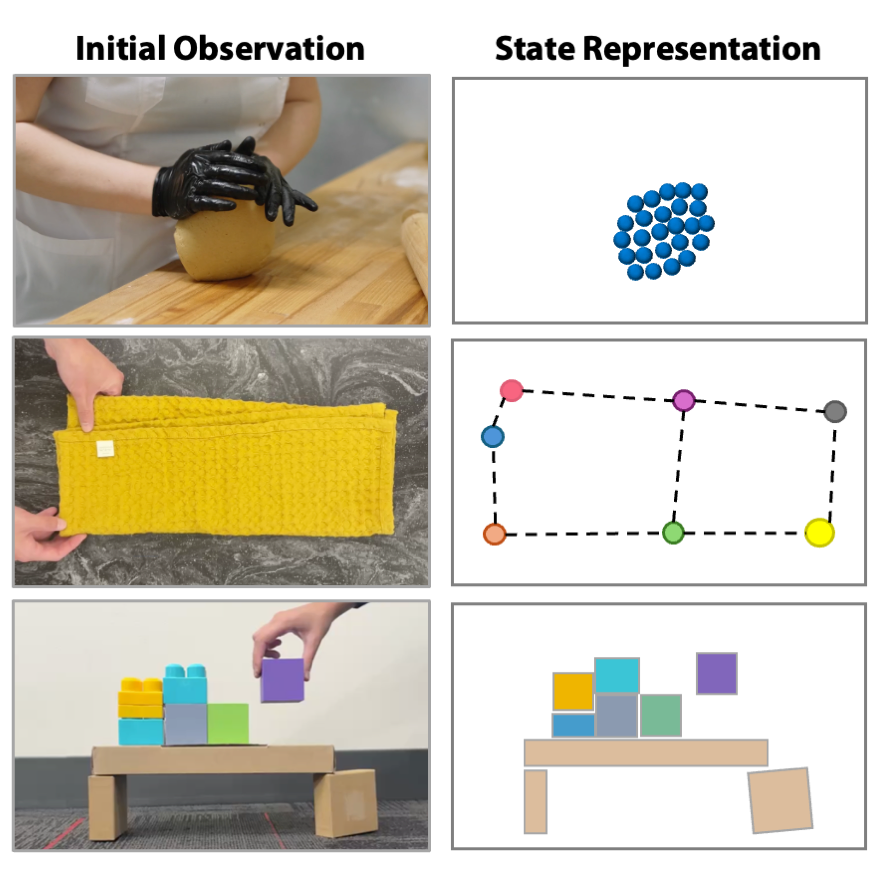
A robot system that learns how soft materials deform and uses different tools to shape them through a sequence of actions.

Minimalist Compliance Control

Haochen Shi*, Songbo Hu*, Yifan Hou, Weizhuo Wang, C. Karen Liu, Shuran Song

*Equal contribution, Equal advising

RSS, 2026

A method that lets robots yield to contact using motor current or voltage signals, without force sensors or learning. Demonstrated on a robot arm, a dexterous hand, and two humanoids.

Handroid: Bridging Dexterous Hand and Humanoid

Ruogu Li, Chenyang Ma, Sikai Li, Zhenyu Wei, Yunchao Yao, Haochen Shi, C. Karen Liu, Shuran Song, Mingyu Ding

arXiv, 2026

A reconfigurable robot that works as both a dexterous hand and a humanoid, supporting manipulation, locomotion, and tasks that combine the two.

Locomotion Beyond Feet

Tae Hoon Yang*, Haochen Shi*, Jiacheng Hu*, Zhicong Zhang, Daniel Jiang, Weizhuo Wang, Yao He, Zhen Wu, Yuming Chen, Yifan Hou, Monroe Kennedy III, Shuran Song, C. Karen Liu

*Equal contribution, Equal advising

Arxiv, 2026

A system that lets humanoids use hands, knees, elbows, and feet to move through obstacles, low spaces, and stairs.

Robot Trains Robot: Automatic Real-World Policy Adaptation and Learning for Humanoids

Kaizhe Hu*, Haochen Shi*, Yao He, Weizhuo Wang, C. Karen Liu, Shuran Song

*Equal contribution, Equal advising

CoRL, 2025

A robotic arm supports and guides a humanoid as it learns and adapts movement skills in the real world.

dynamics review
A Review of Learning-Based Dynamics Models for Robotic Manipulation

Bo Ai, Stephen Tian, Haochen Shi, Yixuan Wang, Tobias Pfaff, Cheston Tan, Henrik I. Christensen, Hao Su, Jiajun Wu, Yunzhu Li

Science Robotics, 2025

A review of models that learn to predict how objects move and change during manipulation, and how robots use those predictions to plan and control their actions.

FürElise: Capturing and Physically Synthesizing Hand Motions of Piano Performance

Ruocheng Wang*, Pei Xu*, Haochen Shi, Elizabeth Schumann, C. Karen Liu

*Equal contribution

SIGGRAPH Asia, 2024

A dataset of 3D hand motion and audio from 15 pianists, supporting research on capturing and physically reproducing piano-playing motions.

DexCap: Scalable and Portable Mocap Data Collection System for Dexterous Manipulation

Chen Wang, Haochen Shi, Weizhuo Wang, Ruohan Zhang, Li Fei-Fei, C. Karen Liu

RSS, 2024

A portable system for recording human hand movements, paired with a method for teaching robots dexterous manipulation from those recordings.

RoboPack: Learning Tactile-Informed Dynamics Models for Dense Packing

Bo Ai*, Stephen Tian*, Haochen Shi, Yixuan Wang, Cheston Tan, Yunzhu Li, Jiajun Wu

*Equal contribution

RSS, 2024

Abridged in ICRA 2024 workshops: ViTac, 3DVRM, and Future Roadmap for Manipulation Skills

A method that combines vision and touch to predict how objects respond to contact, helping robots push objects and pack them tightly.

RoboCraft: Learning to see, simulate, and shape elasto-plastic objects in 3D with graph networks

Haochen Shi*, Huazhe Xu*, Zhiao Huang, Yunzhu Li, Jiajun Wu

*Equal contribution

The International Journal of Robotics Research (IJRR) · Journal extension of RoboCraft (RSS 2022)

A journal extension of RoboCraft that learns how deformable materials behave and plans tool motions to shape them into 3D targets.

RoboCraft: Learning to See, Simulate, and Shape Elasto-Plastic Objects with Graph Networks

Haochen Shi*, Huazhe Xu*, Zhiao Huang, Yunzhu Li, Jiajun Wu

*Equal contribution

RSS, 2022

Abridged in ICRA 2022 workshop on Representing and Manipulating Deformable Objects

Covered by [MIT News] [Stanford HAI] [New Scientist]

A system that learns to predict how deformable objects change shape and uses those predictions to plan how to shape them with tools.

CollisionIK: A per-instant pose optimization method for generating robot motions with environment collision avoidance

Daniel Rakita, Haochen Shi, Bilge Mutlu, Michael Gleicher

ICRA, 2021

A motion-planning method that moves a robot toward a desired pose while avoiding obstacles in its environment.